Hi, I’m Longyan Pan, a master’s student in Artificial Intelligence at Shenzhen University and a member of the Guangdong Provincial Key Laboratory of Urban Spatial Information Engineering. My academic work explores spatial optimization and reinforcement learning, alongside mining large-scale trajectory data. I have also worked closely with the embodied intelligence industry, first as an algorithm intern at Yunmoxing AI and MORPHI Robot. I now work at Xianova Robotics as an Embodied Data Closed-Loop Engineer, focusing on the generalization of simulation data. My greatest aspiration is a world in which everyone can live with prosperity and freedom.
Shenzhen University · Artificial Intelligence 深圳大学 · 人工智能
M.S. / 硕士
Advisors / 导师:Associate Professor Jizhe Xia (夏吉喆) · Assistant Professor Changxin Huang (黄畅昕)
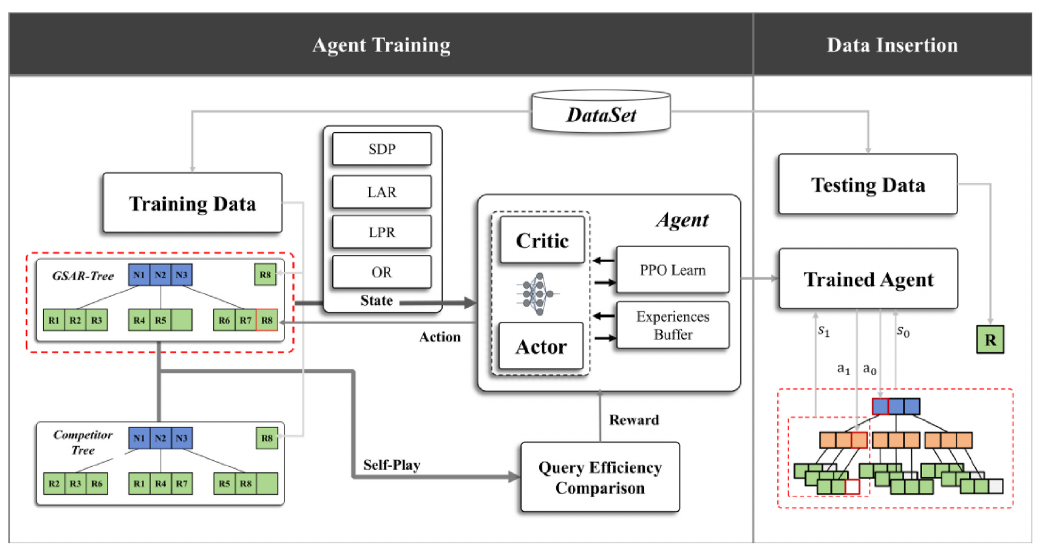
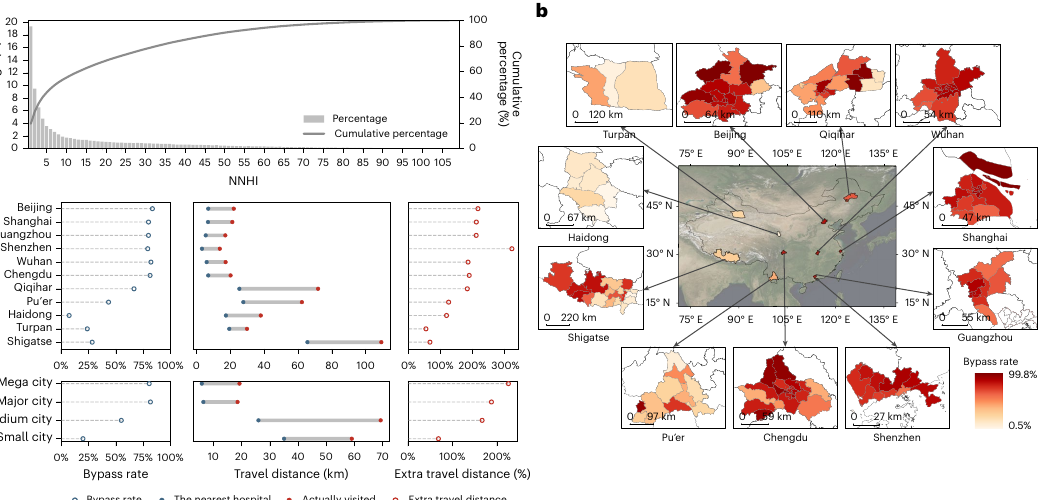
Model spatial decision-making with reinforcement learning to improve access to urban healthcare facilities.以强化学习刻画空间决策过程,探索提升城市医疗设施可达性的优化方法。
Develop high-performance parallel computing frameworks to uncover causal mechanisms in human mobility from massive trajectory datasets.设计高性能并行计算框架,从海量轨迹数据中识别人类出行行为的因果机制。
Chongqing Normal University · Urban and Rural Planning 重庆师范大学 · 城乡规划
Bachelor’s / 学士
Advisor / 导师:Dr. Yong Wu (吴勇)
Focused on large-scale urban simulation and spatiotemporal modeling of land-use change.专注于大规模城市仿真与土地利用变化的时空模拟。
03 /
Experience 工作经历
Embodied Data Closed-Loop Engineer · Xianova Robotics
具身数据闭环工程师 · 夏仙创新
Data Team / 数据组
Build a full-cycle pipeline for SparkInifinity multimodal simulation data across robot embodiments and scenarios: generation, model evaluation, and data-mix optimization. Integrate these stages into a unified feedback loop to break down silos in embodied AI data.
Developed multimodal whole-body human pose estimation models and built a closed-loop workflow spanning data collection, model training, evaluation, and motion optimization.
参与多模态整身人体位姿估计模型研发,搭建从数据采集、模型训练与评估到动作优化的完整闭环。
Algorithm Intern · Yunmoxing AI
算法实习生 · 陨墨星人工智能有限公司
Algorithms Team / 算法组
Developed end-to-end and gait-perception models for exoskeleton robots. Worked across motion-capture collection, annotation, training, and on-device deployment to enable integrated perception and control.
Applied graph neural networks to model transaction patterns in B2B cross-border e-commerce and identify potentially anomalous transactions with greater precision.
运用图神经网络建模 B2B 跨境电商交易行为,提升潜在异常交易的识别精度。
04 /
News & Updates 消息动态
Joined Xianova Robotics as an Embodied Data Closed-Loop Engineer, focusing on simulation data generalization across embodiments and scenes.